Projects
Robotic Assistive System for Human Transfer
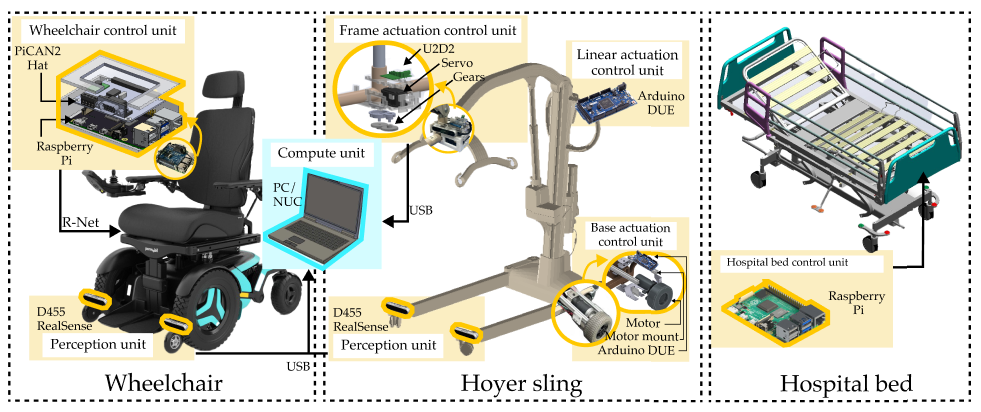
Architected a fully autonomous patient transfer system integrating proxy-perception and diffusion-policy grasp planning to localize and manipulate non-rigid sling hardware with sub-centimeter precision. Designed custom embedded control loops (Arduino/RPi) for retrofitted medical hardware, implementing hardware-level safety overrides and achieving a 97% autonomous success rate (up from 55%).
Fast Goal-Conditioned Diffusion Policy (FGDP)
Formulated a rectified-flow diffusion policy for robotic manipulation that decouples inference latency from generation quality, introducing a tunable K-step knob to optimize the real-time accuracy–latency frontier. Outperformed baseline diffusion models in low-latency regimes (K=1) by enforcing trajectory smoothness during training, validating superior action-chunk consistency across high-dimensional control tasks.
HemiSec (NIR Biometric Authentication)
Designed a hardware-software NIR imaging pipeline for palm-vein biometrics, implementing a CV stack including Otsu-based segmentation, distance-transform "safe masks," robust illumination correction, and a Gabor filter-bank feature descriptor with spatial grid pooling for lighting-invariant matching.
Under Construction
A small game I'm building solo, just for fun.